Oct
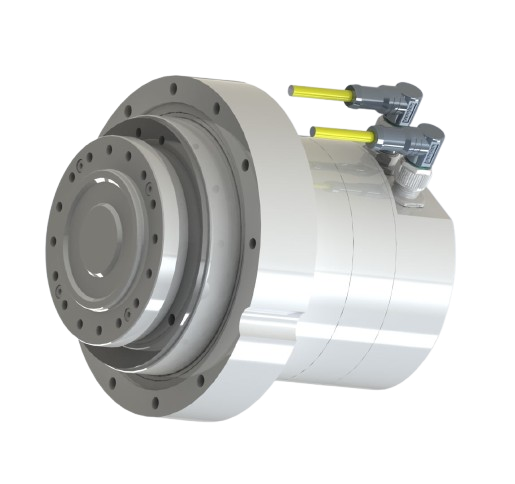
Robot3T introduces VJ-03-CAN, the CAN bus version of the VJ-03 robot joint. It keeps the same motor, harmonic gear and torque range of up to 328 Nm, but is controlled over CAN 2.0A at 1 Mbit/s and built into a fully enclosed housing with screw-locking M12 connectors.
Why a CAN version?
VJ joints in our VietCobot arms run on EtherCAT. EtherCAT is excellent for synchronizing many axes, but it needs an EtherCAT master and a real-time PC. Many customers building their own robots, mobile platforms or teaching labs need something simpler. With VJ-03-CAN, an STM32 microcontroller, a PLC with a CAN port or a PC with a USB-CAN adapter can read position and command position or speed with just a few messages.
Key points
- All-in-one, fully enclosed: BLDC motor, harmonic gear (ratio 50 / 80 / 100), driver, 20-bit multi-turn absolute encoder and brake in one unit.
- Compact protocol: 16 commands, CANopen-style 11-bit IDs, up to 127 joints on one bus.
- Keeps position through power loss: a 3.6 V battery backs the encoder, so no homing at every start-up.
- Safe: fail-safe brake, command watchdog and broadcast emergency stop.
- 24–48 VDC supply, with position, speed and hand-guiding modes.
Each joint ships with a full CAN integration manual and sample code. See the specifications, command set and wiring on the VJ-03-CAN product page.
Building your own robot or motion axis? Contact us for a recommendation and a quote.