SOLUTION · EDUCATION AND RESEARCH

Real robots for classrooms and research labs.

Robot3T EDU Lab is a complete package of equipment, software and curriculum for universities, colleges, vocational schools and research groups. Students learn on the same VietCobot collaborative robots and R3T industrial robots that run in factories, designed and built in Vietnam.

Get a consultation
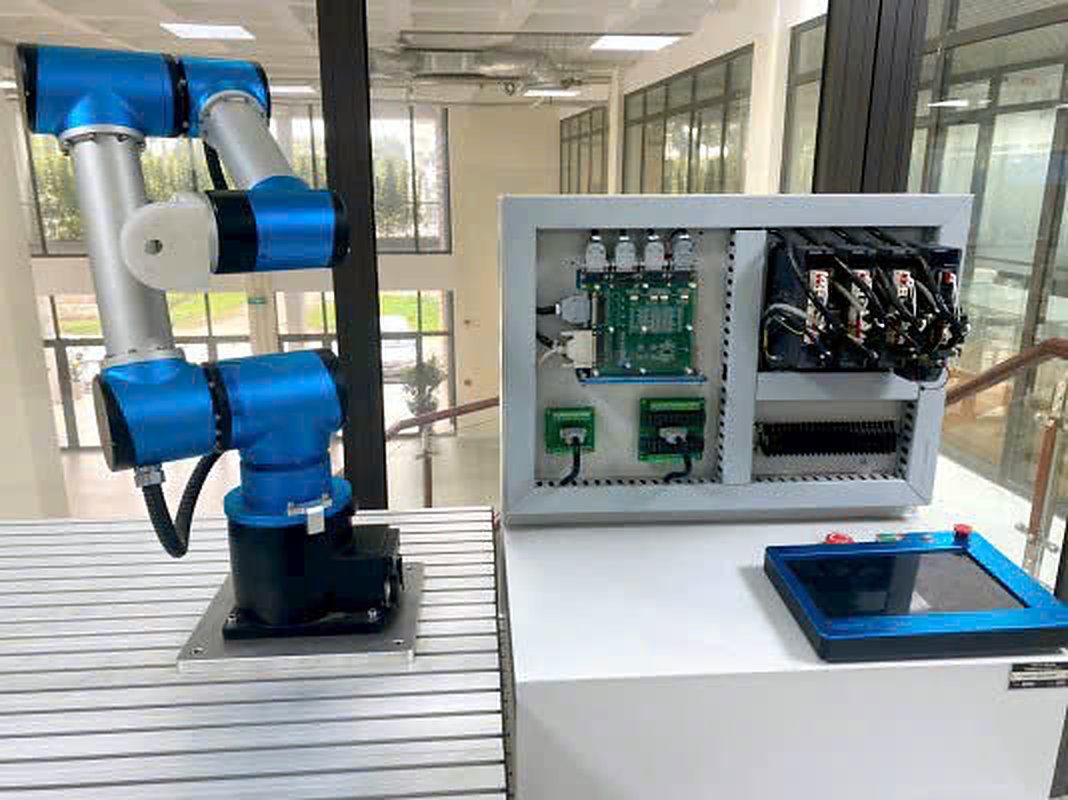
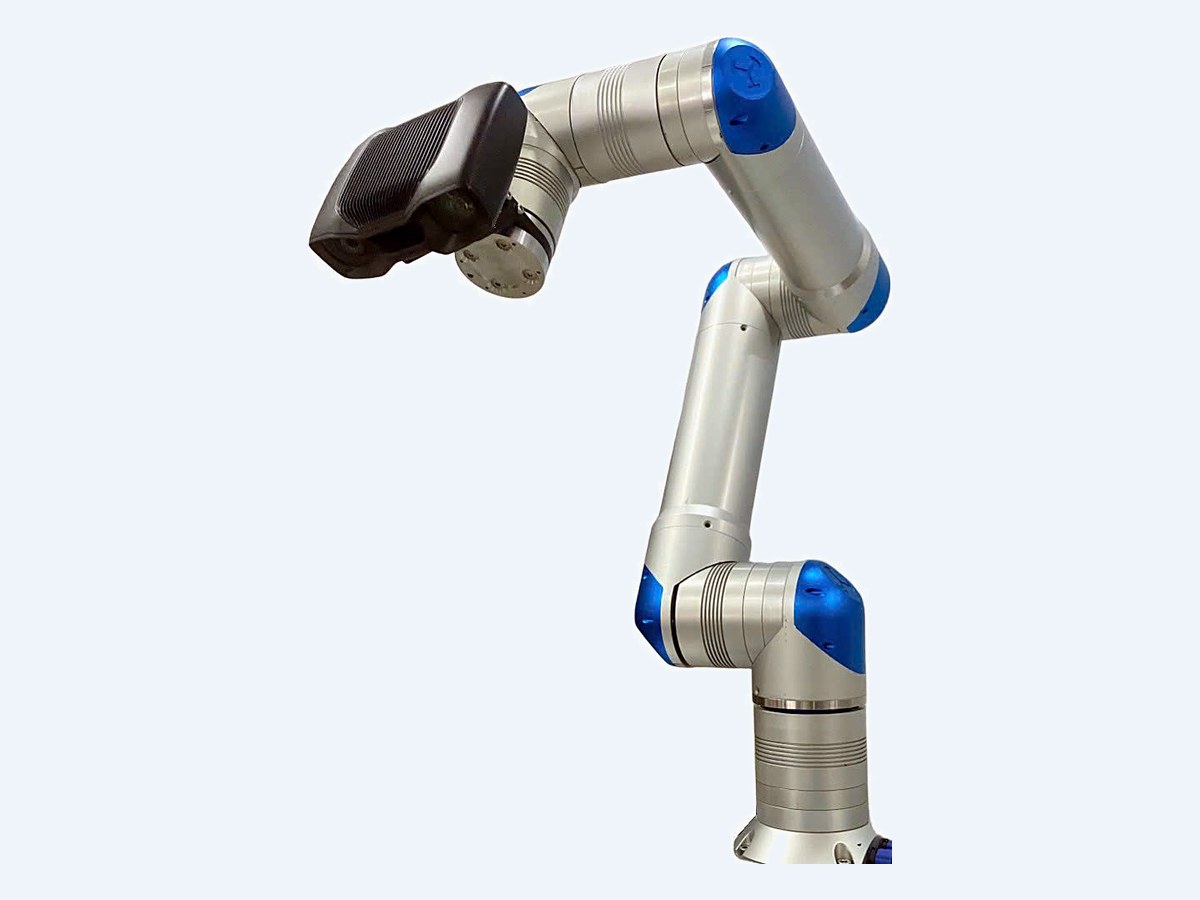
R3T industrial robot training station with control cabinet and teach pendant

3 packagesfrom first steps to research
9 moduleswith ready-made labs on real robots
Safecobots work beside people, no fencing needed
CAN · EtherCATopen down to every robot joint

THE CHALLENGE

Students need to learn on robots like the ones in real factories.

Models are not real robots

Model robots teach the concepts, but graduates still struggle with real robot arms, control cabinets and industrial communication standards.

Closed systems limit teaching

Locked-down software and controllers make it hard to teach kinematics and control in depth, or to run research projects on real hardware.

PLC and vision taught in isolation

Schools teach PLC and image processing, but have no way to bring them together on a robot, so students never see the knowledge work in a real system.

THE SOLUTION

Robot3T EDU Lab: one platform, three levels of learning.

Teach by hand guiding

Guide the cobot by hand along the path, and it remembers and repeats it. Students control a real robot from the very first lesson.

Open programming

Control the robot from a PC with the Python SDK, REST API and ROS 2 support, on one platform from intro classes to research projects.

Simulate first, then run

Write and test programs on the computer before running them on the robot, safe for people and equipment.

PLC and vision on the robot

2D and 3D cameras plus PLC connectivity bring both subjects together in a working robot cell.

Open down to the joint

VJ robot joints are sold individually with CAN or EtherCAT, so labs can build their own robots and write their own algorithms.

Labs from the factory floor

Pick-and-place, welding, spraying, camera inspection: applications Robot3T has deployed, packaged as lab exercises.

PACKAGES

EDU Start, EDU Pro, EDU Research.

Each package has clear learning goals and prepares the way to the next one. Every robot in the solution runs on the same control platform, so lessons from one package carry over when the school upgrades.

EDU Start EDU Pro EDU Research
For Vocational schools, colleges, intro courses; robotics enthusiasts Faculties and departments; 3rd–4th year students, capstone projects Research labs, research groups, graduate students
Goal First steps, confident robot operation, intro to kinematics Bring PLC and image processing onto the robot for more applications Study cobot dynamics
Robot VC0401 desktop cobot; optional R3T-01-E industrial robot VC0403 / VC0503 VC0603
Equipment Servo gripper, teach pendant, simulation mode, Kinematics software EDU Start plus 2D and 3D cameras, PLC connectivity, Python SDK, REST API EDU Pro plus 6-axis force/torque sensor, Dynamic Simulation software, ROS 2
Modules 1–3 1–6 1–9
Instructor training Operation, safety, kinematics Application programming, camera and PLC integration Modeling, algorithm development

CURRICULUM · 9 MODULES

From robot operation to dynamics.

EDU Start · Modules 1–3

  1. Introduction to collaborative and industrial robots: structure, coordinate systems, safety.
  2. Teach pendant operation and programming: waypoints, MoveJ, MoveL, I/O, hand guiding, pick-and-place with the servo gripper.
  3. Forward and inverse kinematics and trajectory planning with the Kinematics software.

EDU Pro · Modules 4–6

  1. Robot vision with 2D and 3D cameras: recognition, localization and picking.
  2. Connecting the robot to PLCs, conveyors and sensors; programming with Python and the REST API.
  3. Integration project and capstone: a robot cell combining camera and PLC.

EDU Research · Modules 7–9

  1. Cobot dynamics: modeling and simulation with the Dynamic Simulation software.
  2. Force and torque measurement with a 6-axis sensor, comparing simulation with experiment, force control.
  3. ROS 2 and control algorithm development.

PLC and image processing knowledge is applied directly on the robot, not left as isolated exercises.

EQUIPMENT

Built around VietCobot, made by Robot3T.

6-axis VietCobot collaborative robot with 3D camera

VietCobot collaborative robot

4 to 6-axis cobots, from desktop models up to 1,050 mm reach; teach pendant, EtherCAT, safe to work beside people. Models VC0401 · VC0403 · VC0503 · VC0603.

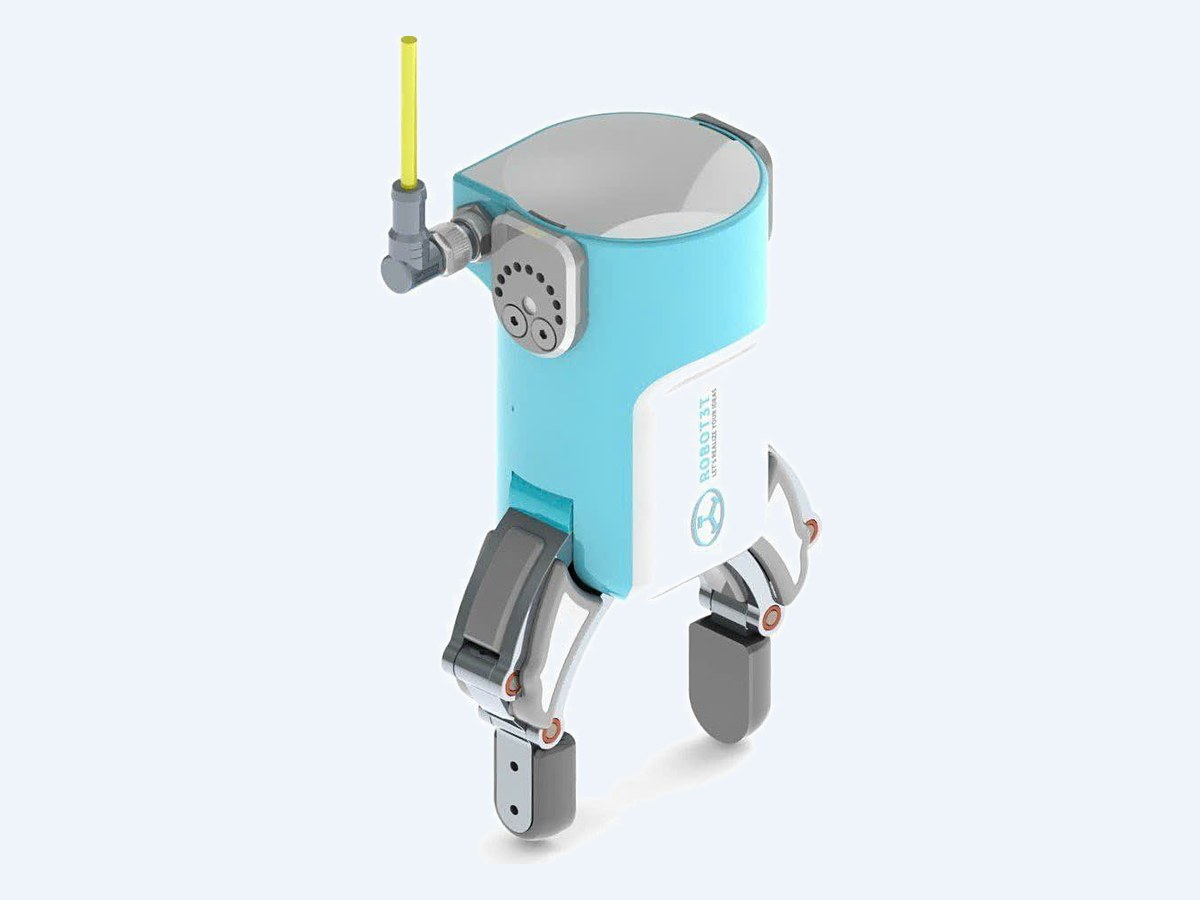
Robot3T servo gripper

Servo gripper

Programmable position, speed and grip force; controlled from the teach pendant, Python SDK and REST API.

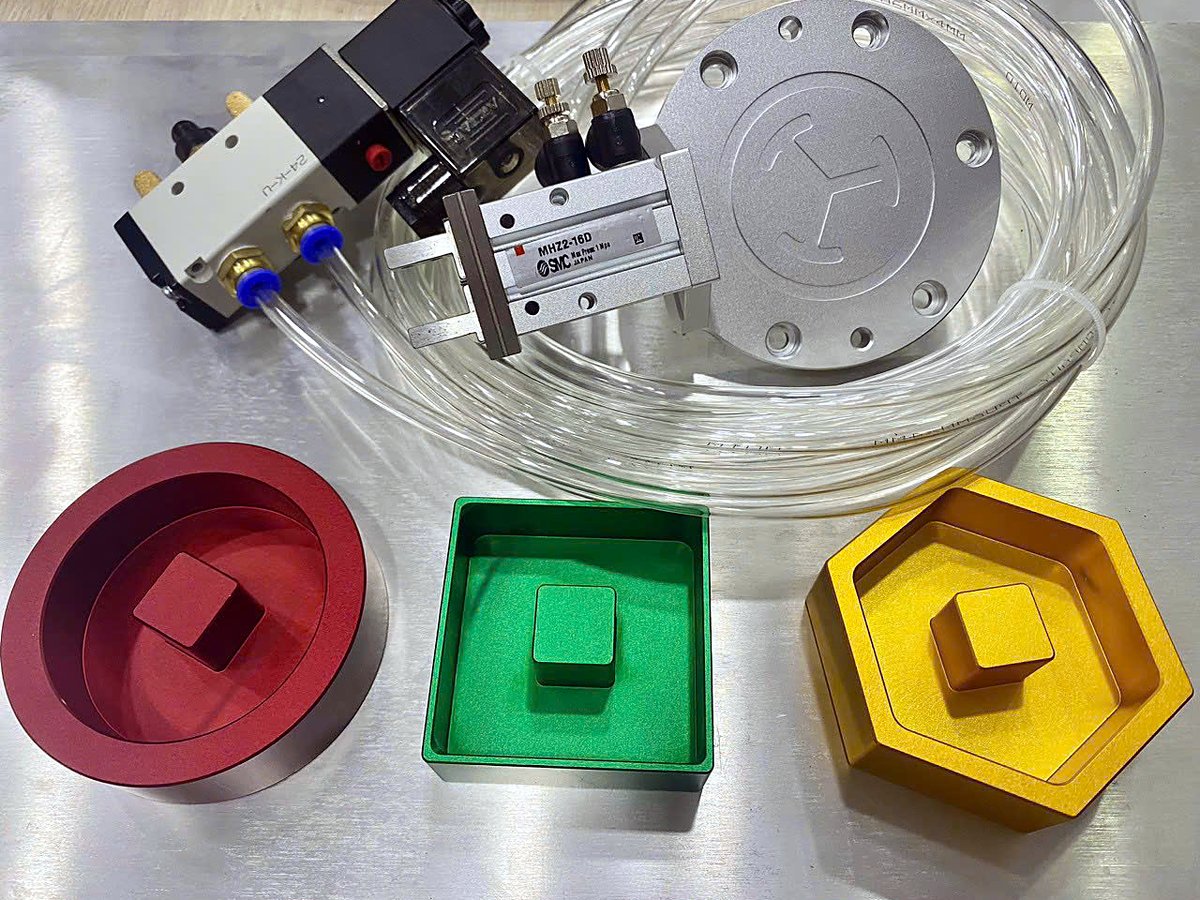
Pneumatic gripper and training parts for pick-and-place and sorting

Pneumatic gripper and training kit

Pneumatic gripper, solenoid valve and a set of shaped parts for pick-and-place and sorting labs from day one.

2D and 3D cameras

2D cameras for recognition, code reading and flat inspection; 3D cameras for measuring and locating parts in space.

Force sensor and PLC

A 6-axis force/torque sensor at the cobot wrist; PLC connectivity to link the robot with production lines, conveyors and automated cells.

Software and documentation

Kinematics and Dynamic Simulation software, Python SDK, REST API, ROS 2 support, simulation mode and training materials.

R3T-01-E industrial robot (optional)

A 5-axis arm on the same control platform as VietCobot, for schools that also teach industrial robotics.

SINGLE ROBOT JOINTS · VJ-01 → VJ-04

Build your own robot, develop your own algorithms.

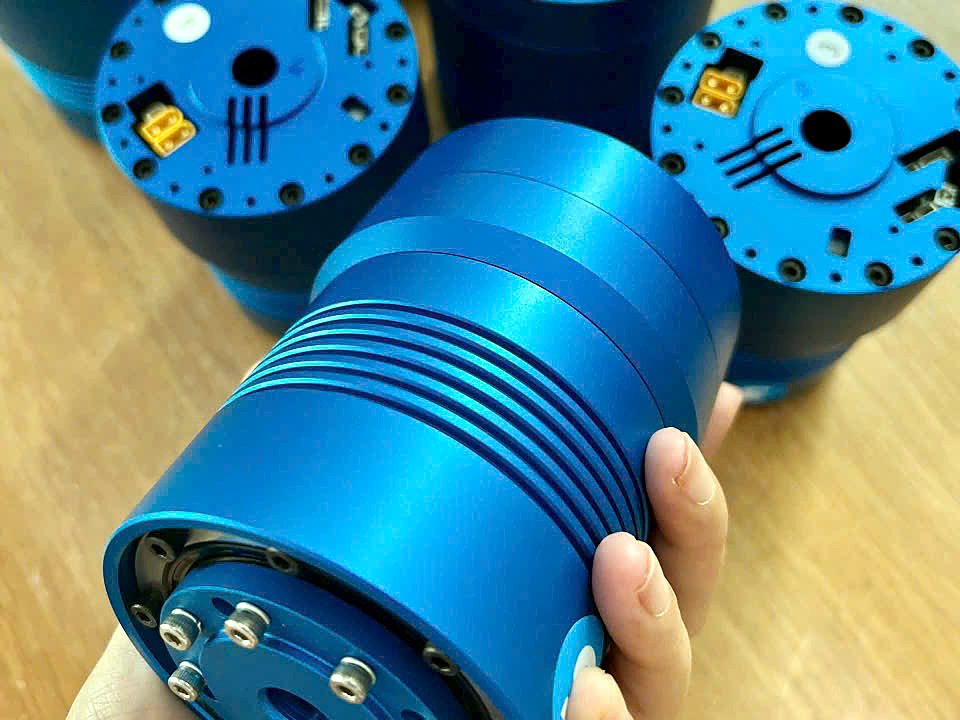
  • Each joint integrates motor, gearbox and driver; just add power and a network connection.
  • CAN (CANopen): easy to start with, suited to microcontrollers and intro labs.
  • EtherCAT: fast control cycles and multi-joint synchronization for real-time research.
  • Choose your own degrees of freedom, robot type and algorithms, on the same joints used in commercial robots.

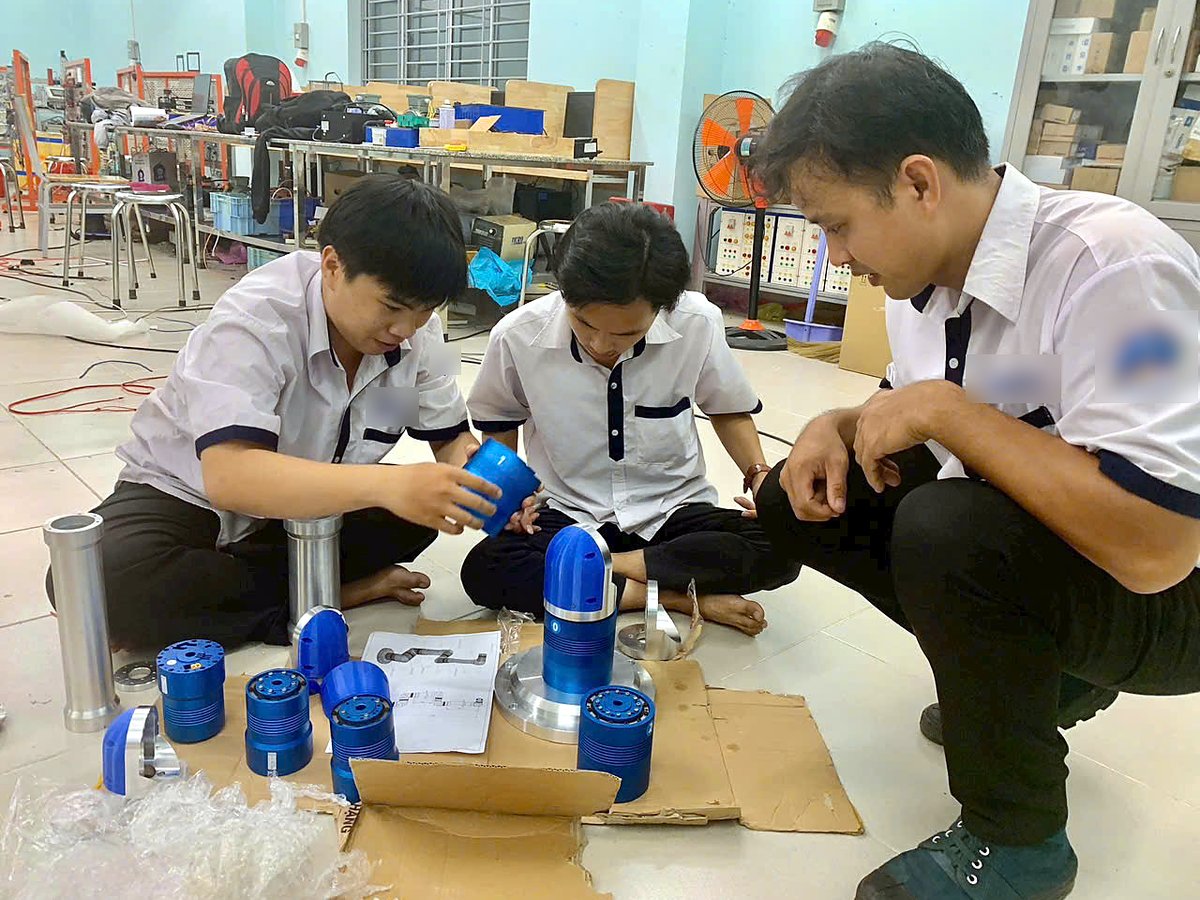
From a real lab: a university used VJ joints to design and assemble a complete robot arm, now running in its own laboratory.

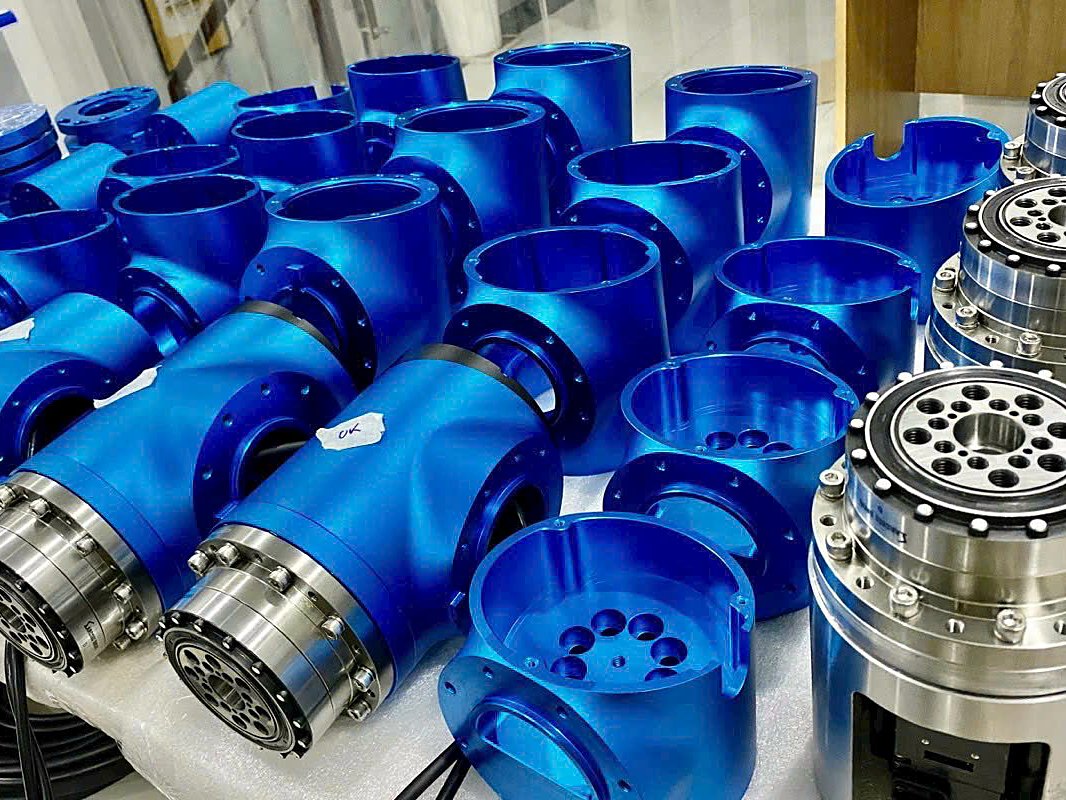
VJ robot joint with integrated motor, gearbox and driver

VJ robot joint: motor, gearbox and driver in one unit.

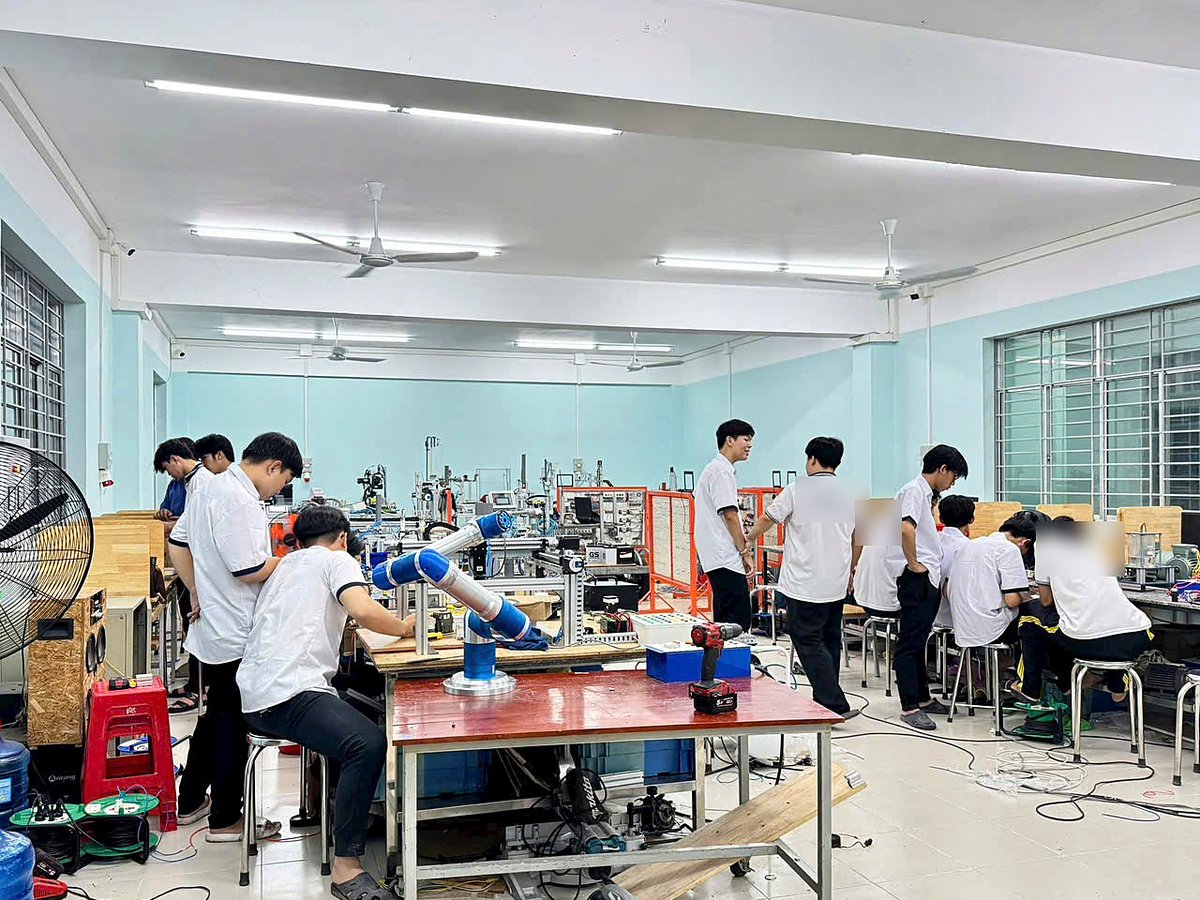
Students assembling a robot arm from VJ joints

Students assembling a robot arm from VJ joints in their university lab.

WHO IT’S FOR

A package for every level of training.

  • Vocational schools, colleges and self-learners: robotics fundamentals and confident operation on a real cobot.
  • University faculties and departments: 3rd–4th year courses and capstone projects combining robot, camera and PLC.
  • Research labs and groups: dynamics, force control, custom robots built on VJ joints.

Collaborative robot training class

Robot joint components machined and assembled by Robot3T

Why Robot3T

  • Real factory cobots: the same VietCobot line used for spraying, palletizing, welding and assembly in factories in Vietnam.
  • Safe in the lab: cobots work right beside students without fencing, ideal for large classes.
  • Core technology in-house: we design our own joints, controllers and software, so we can open them up for teaching and research.
  • Budget-friendly: designed and built in Vietnam, with investment package by package.
  • Direct support: engineers and spare parts straight from the manufacturer, supporting instructors from the first lab to research projects.

TURNKEY DELIVERY

From site survey to long-term support.

01

Survey

We work with your faculty on curriculum, class size, space and budget.

02

Lab design

Choose the package, lay out the stations, propose modules and labs.

03

Installation

Robots, control cabinets, workbenches and software installed on site.

04

Training

Instructor training in operation, programming and safety, with materials and sample labs.

05

Support

Technical support, software updates, equipment expansion and research collaboration.

Want to see the robots running for your lab?

Tell us about your curriculum and training space. Robot3T engineers will recommend a configuration and arrange a demo.

Get a consultation & book a demo